Drone Swarm

  1. Home
  2. Drone Swarm

Autonomous Drone Swarm “Like Bees”

A design and programming effort for an autonomous swarm of approximately 50 drones, with approaches to communication between neighbouring drones and to pathfinding for the group. It began in the student robotics team that I founded at the University of Nicosia.

Related NeoSwarm and Vector concepts apply the idea to autonomous logistics and to firefighting in Cyprus. The software side separates flight-critical real-time code from companion logic for missions, planning and perception.

  • Category :Embedded Systems / Multi-Agent
  • Stack :Arduino, Python companion modules
  • Scale :Concept of about 50 drones
  • Focus :Communication and pathfinding
  • Applications :Autonomous logistics, firefighting
  • Status :Concept and documented architecture
  • Concept page :Vector investor page

Core Features

A swarm is a communication and software-architecture problem before it is a flying problem, so the project starts from the structure.

  • Mesh-style communication between neighbouring agents.
  • Pathfinding approaches for the whole group.
  • Arduino-based embedded control nodes.
  • Real-time autopilot code kept separate from the companion computer.
  • Companion modules for mission, planning, perception, communication and logging.
  • Message contracts shared between modules.

“Keep flight-critical logic and companion logic separate, and let message schemas be the contract between them.”

Design Note - Safety Boundary

Architecture

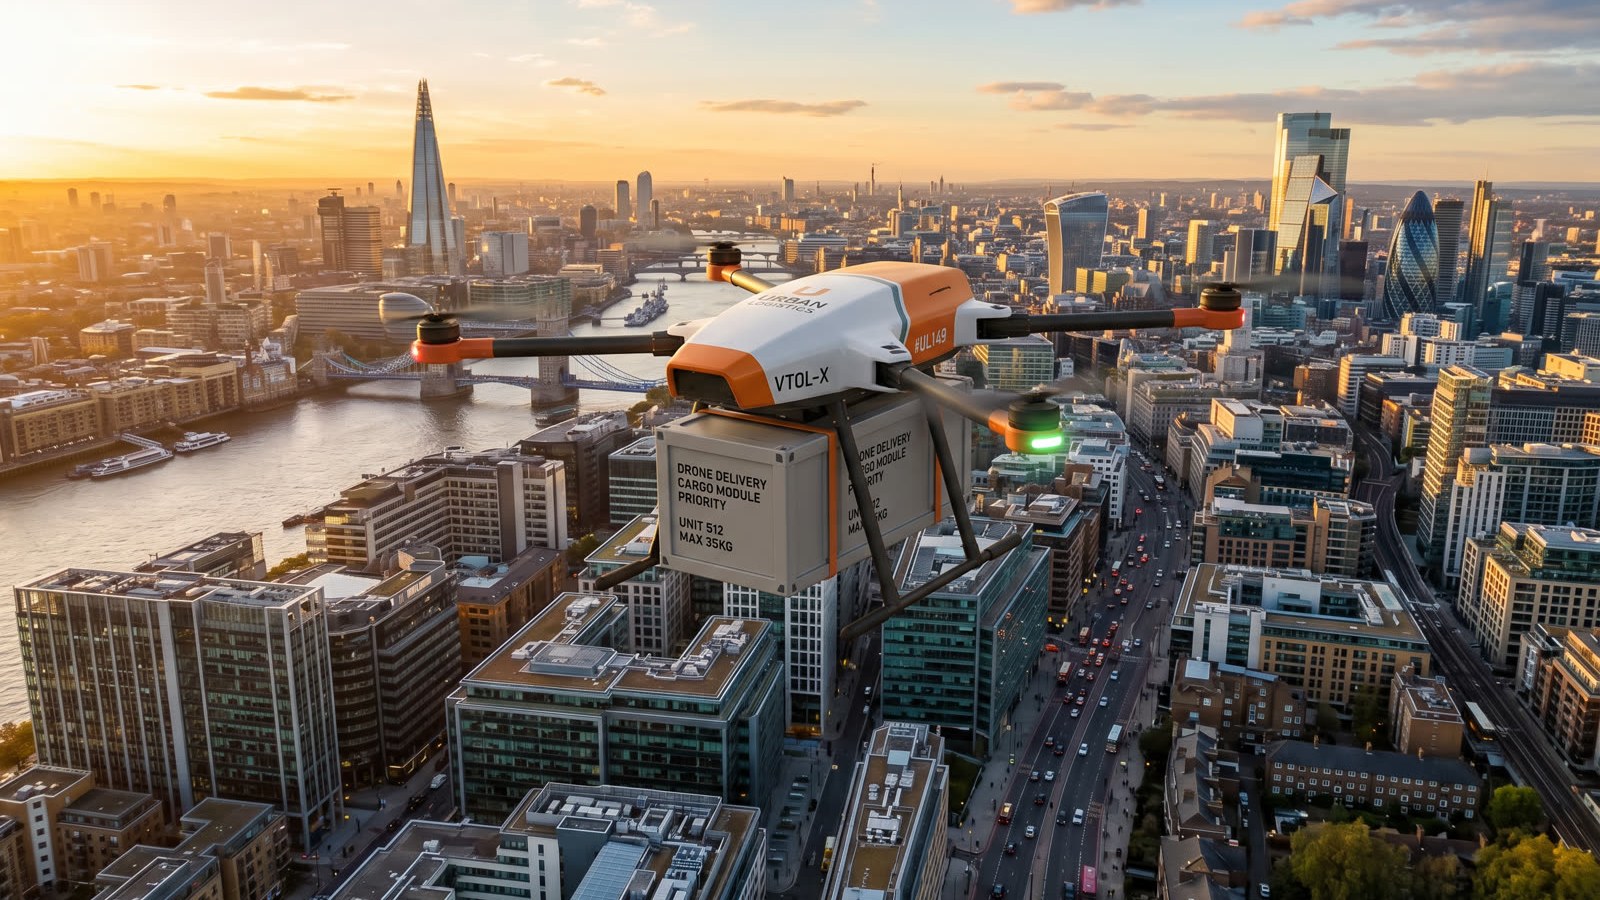
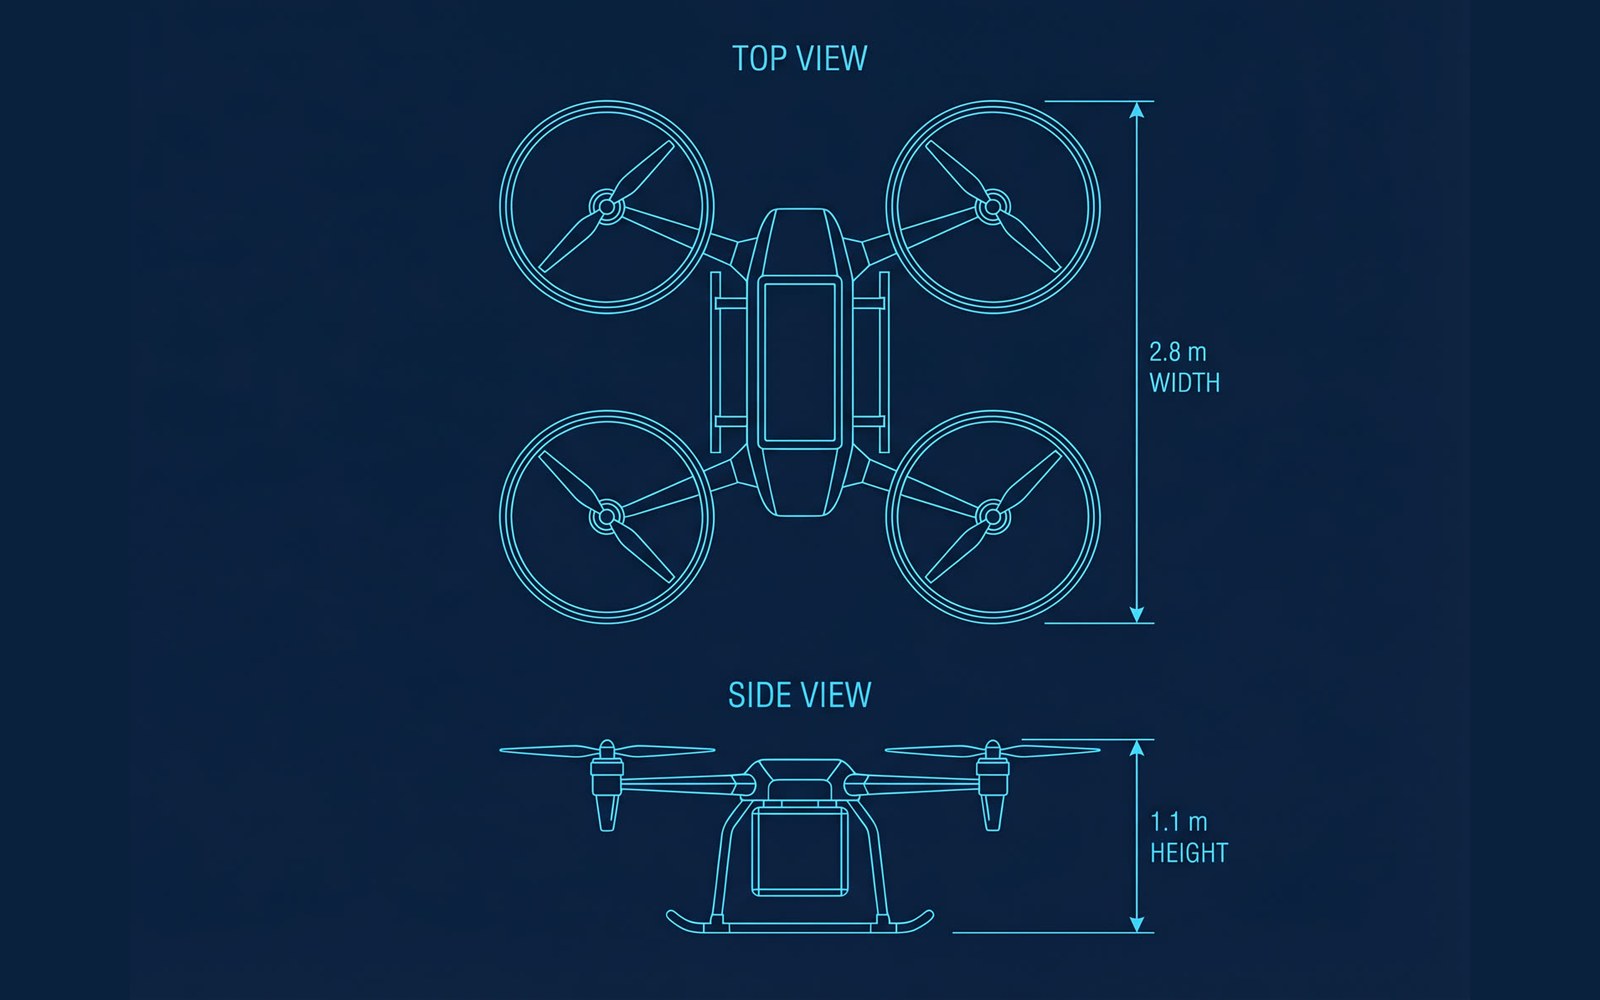
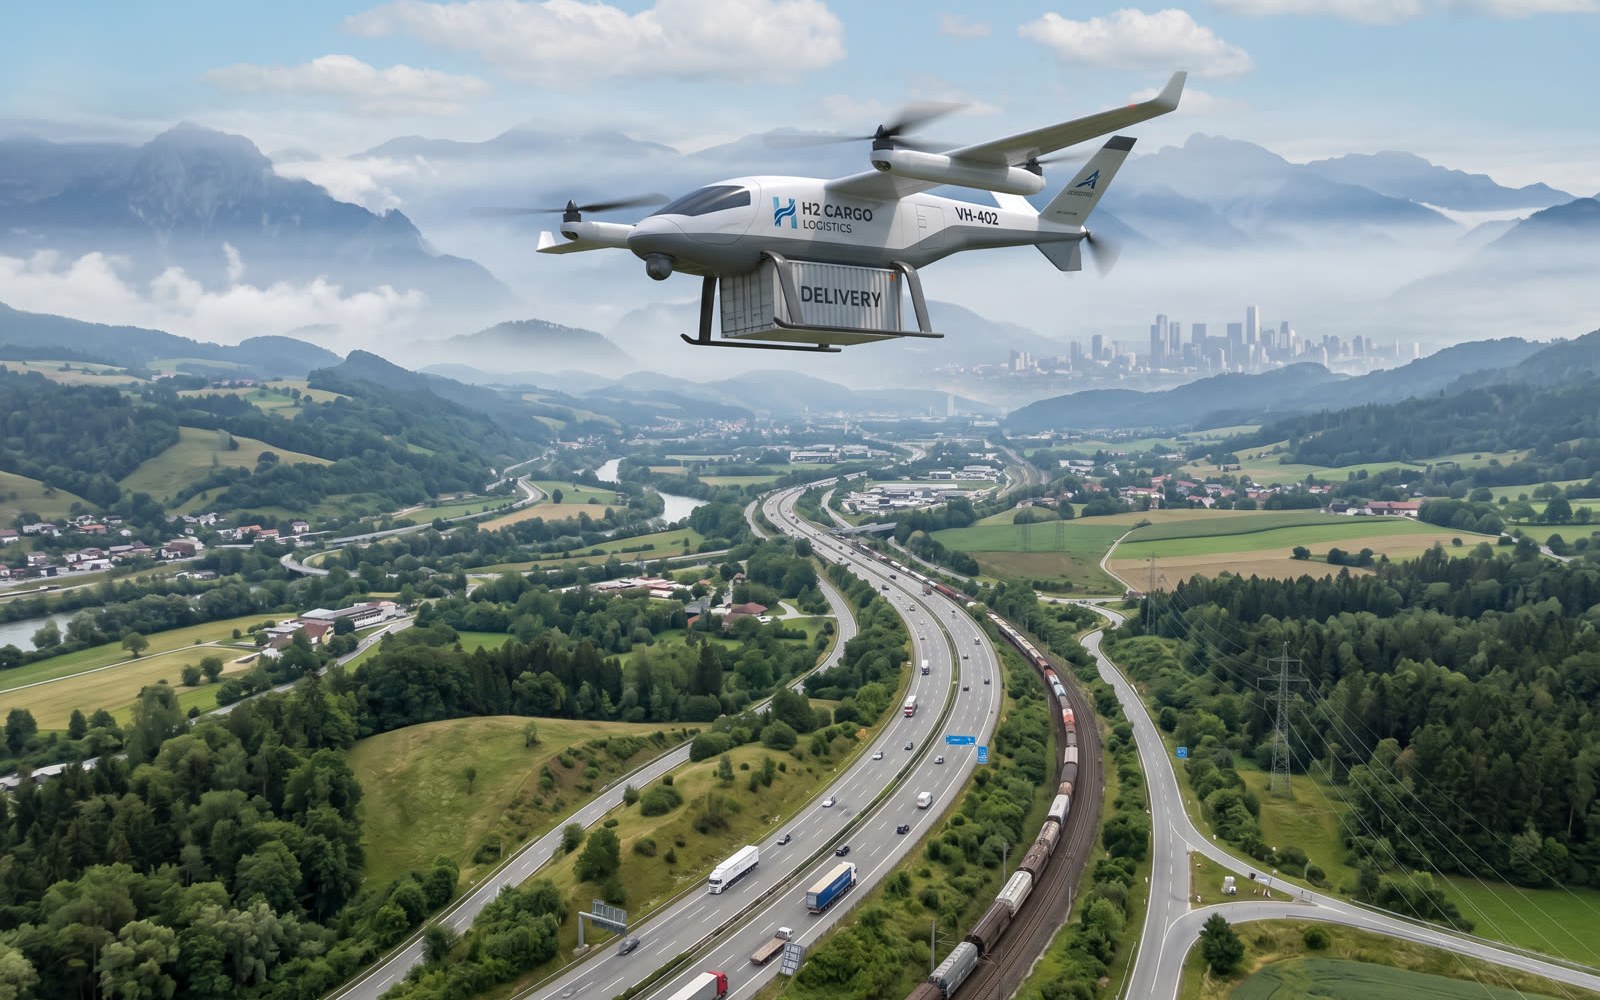
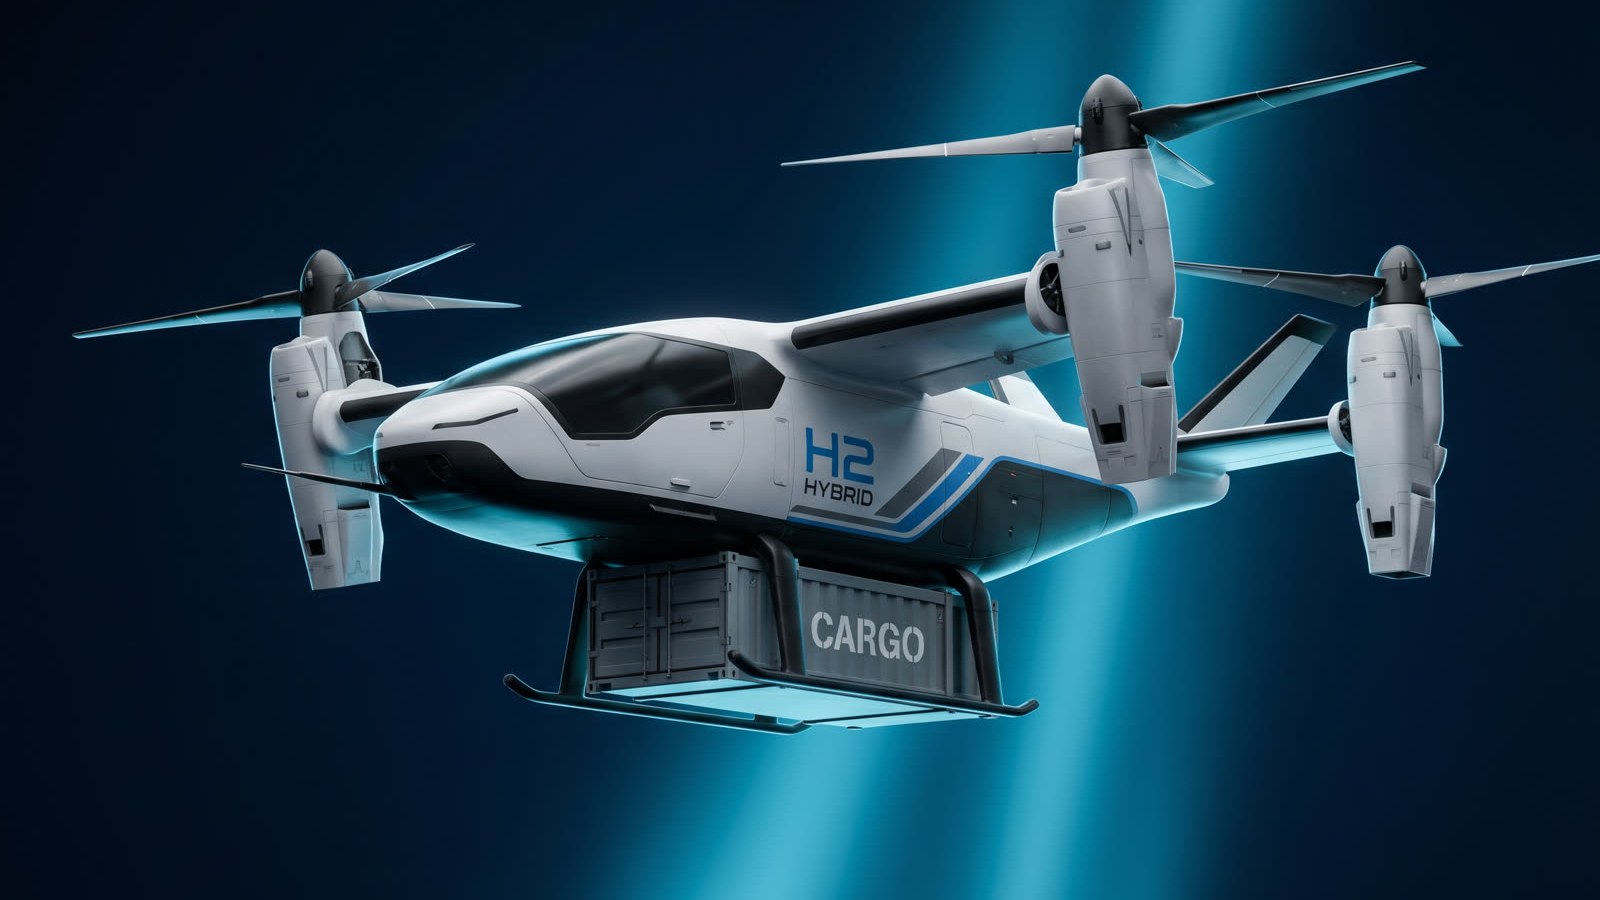
The software is split into two worlds. The real-time side holds flight-critical code or autopilot configuration and stays independent of the companion. The companion side is Python: a mission manager that issues commands and safety events, a planner that produces a path plan, and perception that produces an obstacle map. Shared message types connect them. Real hardware and simulation assumptions still have to be verified before deployment. The images on this page come from the Vector concept: the VTOL cargo drone, its blueprint, an urban delivery scene and a cargo flight over a highway. They are concept renders, not photographs of a built aircraft.

Mission Flow

  • Telemetry arrives at the mission manager.
  • The mission manager issues commands and raises safety events.
  • The planner produces a path plan.
  • Perception produces an obstacle map.
  • Message contracts connect all modules.
  • The real-time autopilot executes the flight.

What It Shows

  • Embedded and multi-agent system design.
  • A deliberate safety boundary between real-time and companion code.
  • Leadership of a student robotics team.
  • Concepts for logistics and firefighting in Cyprus.

Related Projects

LELP: Lunar Electromagnetic Logistics Platform

LELP: Lunar Electromagnetic Logistics Platform

Aerospace Concept / Systems Engineering
Automatic Mafia

Automatic Mafia

Python / PySide6 / Face Recognition
SplitBill

SplitBill

Next.js / TypeScript / Supabase

Project Summary

Send a direct message about this project and it will be delivered to my email.